5-DoF Robotic Arm with Gripper (MG995 Driven)
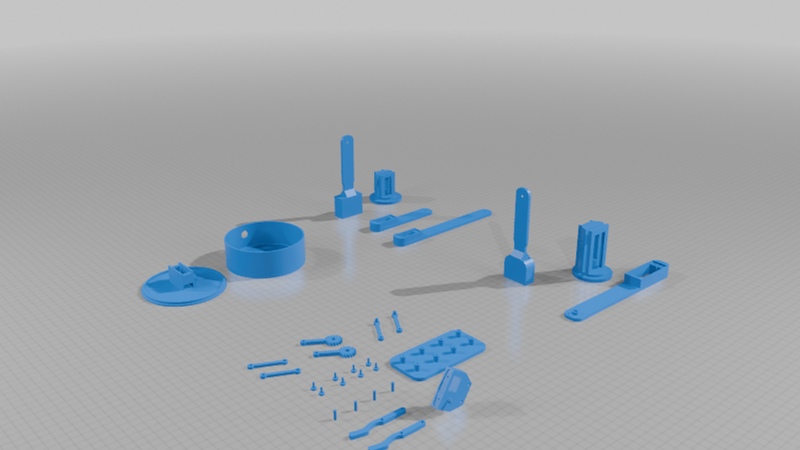
Description
Description
Axiom 5-DoF Robotic Arm Platform — Modular & Open-Control Design
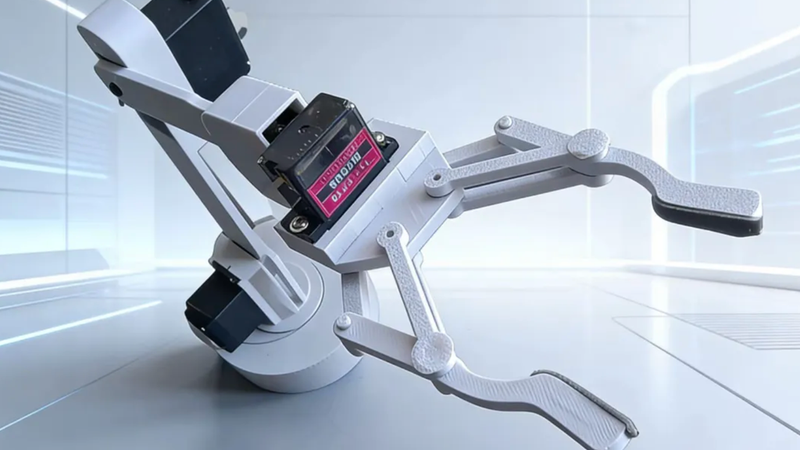
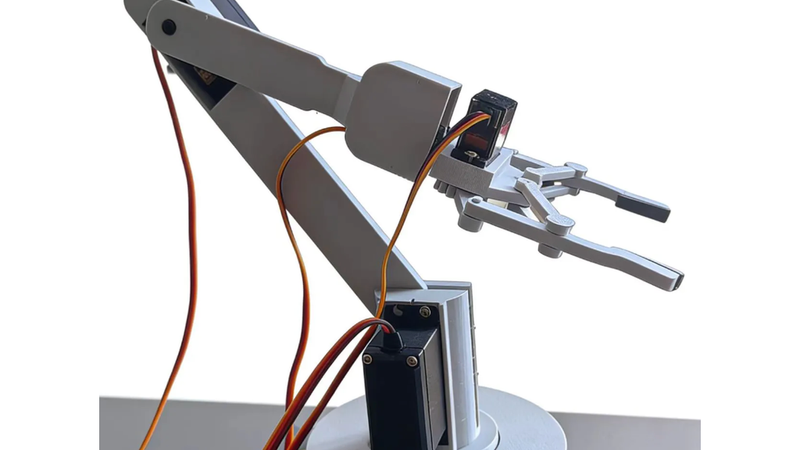
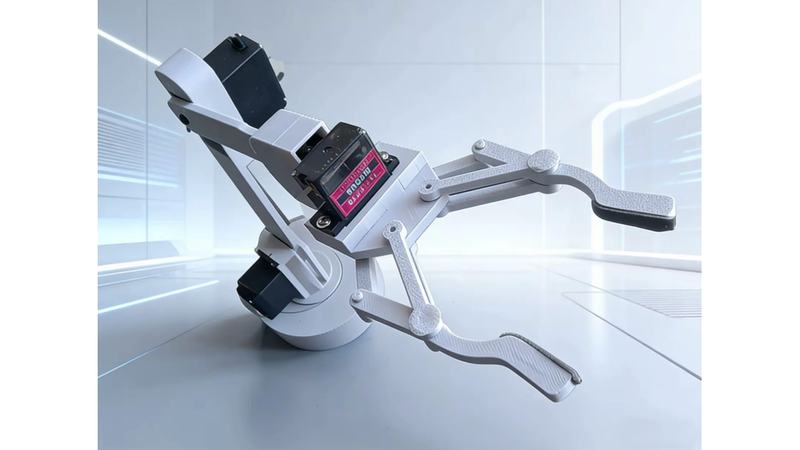
This project provides a complete, 3D-printable 5-DoF robotic arm mechanical structure with a functional gripper.
Freedom to Control It Your Way: The primary release provides the physical mechanics and structure. How you bring it to life is entirely up to you! While my personal setup uses two analog joystick modules (as shown in the photos) for direct manual control, this platform is fully open and compatible with whatever control scheme you prefer:
Arduino / ESP32 / Raspberry Pi firmware control
Custom Code & Kinematics (Python, C++, ROS)
Wireless Control via Bluetooth, Wi-Fi, or Web App
Physical Controls like joysticks, potentiometers, or custom controllers
Hardware Specs & Requirements:
Mechanics: 5 Degrees of Freedom + Parallel Gripper
Arm Actuators: Driven by standard MG995 (or compatible) servos
Gripper Actuators: Requires 2x MG90S micro servos
Printability: Optimized for easy 3D printing without complex supports
Feel free to adapt, modify, and write your own code to give this robotic arm unique behaviors! If you build your own control system, I’d love to see it in the Makes & Comments section!