Mini Maker Robot – Print-in-Place
Description
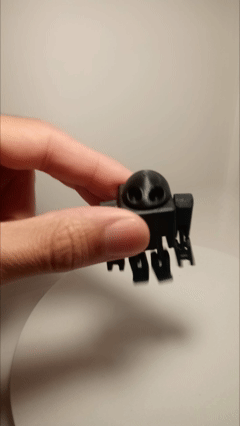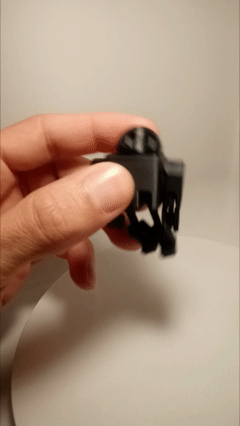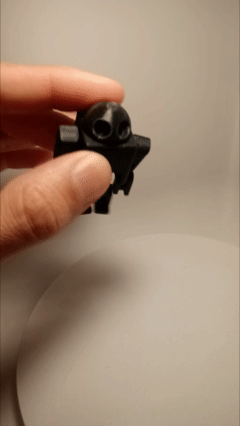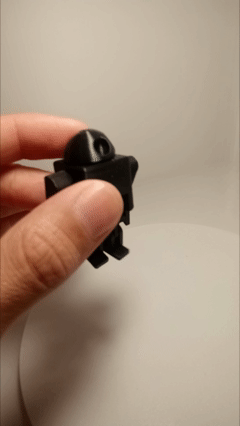
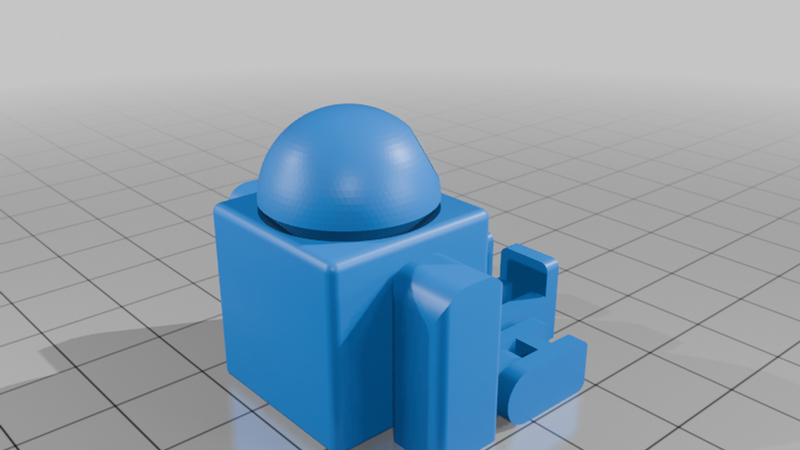
Ein kleiner, simpler und supersüßer Print-in-Place Mini-Roboter im MakerFaire-Stil.
Der Roboter ist vollständig Print-in-Place konstruiert und benötigt nach dem Druck keine Montage. Mehrere Körperteile sind direkt beweglich:
- Kopf – drehbar
- Arme – eindimensional drehbar
- Unterarme – eindimensional drehbar
- Schenkel – eindimensional drehbar
- Füße – eindimensional drehbar
Das Modell wurde ursprünglich mit Blick auf Ender 3 V1 Hardware entwickelt. Deshalb sind die Toleranzen mit etwa 0,5 mm bewusst sehr großzügig ausgelegt. Das soll den Druck auch auf älterer oder nicht perfekt kalibrierter Hardware möglichst unkompliziert machen.
🖨️ Druckinformationen
- Keine Stützstrukturen erforderlich
- Standard-Einstellungen sind ausreichend
- PLA funktioniert
- Eine Haftungshilfe auf der Druckplatte darf gerne verwendet werden, z. B. 3D-Lac oder Klebestift
⚠️ Wichtig: Kopf und Z-Naht
Beim halbkugelförmigen Kopf sollte auf die Position der Z-Naht geachtet werden.
Idealerweise wird die Naht auf die Rückseite des Kopfes gelegt. In OrcaSlicer, Bambu Studio oder Anycubic Slicer kann die Naht entsprechend positioniert bzw. eingezeichnet werden. In Cura kann sie manuell platziert werden.
Eine ungünstig platzierte Naht kann bei dem kleinen Kopf deutlich sichtbar sein und die Optik beeinträchtigen.
🖨️ Drucker-Kompatibilität
Das Modell wurde hauptsächlich auf einem Ender 3 V1 entwickelt und getestet.
Mit einem Bambu-Drucker wurde bisher ein Test in PLA erfolgreich durchgeführt. Dieser war erfolgreich, allerdings wurde das Modell auf Bambu-Druckern bisher noch nicht ausführlich getestet.
Wenn du den Roboter auf einem anderen Drucker ausprobierst, freue ich mich sehr über Feedback und Bilder!
Viel Spaß beim Drucken! 🤖❤️
A small, simple and super cute print-in-place mini robot with a MakerFaire-inspired style.
The robot is designed as a fully print-in-place model and requires no assembly after printing. Several parts can be moved directly after printing:
- Head – rotates
- Arms – rotate in one axis
- Forearms – rotate in one axis
- Thighs – rotate in one axis
- Feet – rotate in one axis
The model was originally developed with Ender 3 V1 hardware in mind. Therefore, the tolerances are intentionally quite generous at around 0.5 mm. This is meant to make the model easier to print, even on older or not perfectly calibrated hardware.
🖨️ Print Information
- No supports required
- Standard print settings are sufficient
- PLA works well
- Feel free to use a bed adhesion aid such as 3D-Lac or a glue stick
⚠️ Important: Head and Z-Seam
Please pay attention to the Z-seam position when printing the hemispherical head.
Ideally, the seam should be positioned on the back of the head. In OrcaSlicer, Bambu Studio or Anycubic Slicer, you can position or paint the seam accordingly. In Cura, the seam can be positioned manually.
A poorly positioned seam can be quite noticeable on the small head and may affect its appearance.
🖨️ Printer Compatibility
The model was primarily developed and tested on an Ender 3 V1.
So far, it has also been successfully tested once on a Bambu printer using PLA. The test was successful, but the model has not yet been extensively tested on Bambu printers.
If you try the robot on another printer, feedback and pictures are always very welcome!
Have fun printing! 🤖❤️