SOLID MODELRobotic Arms & Automation19-Sept-2026
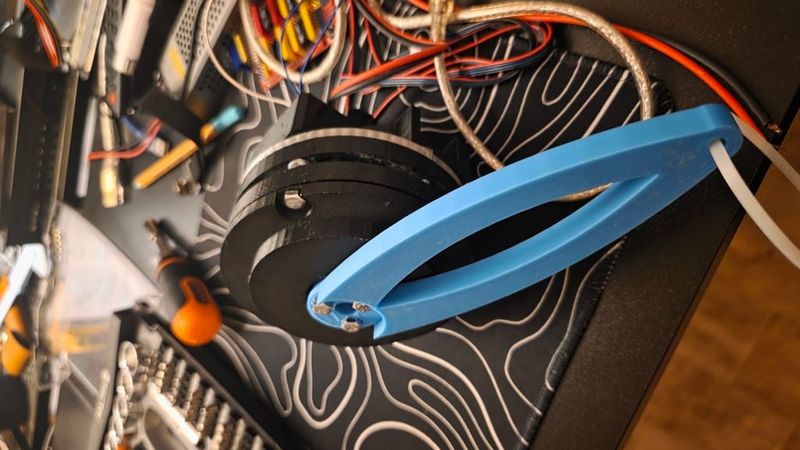
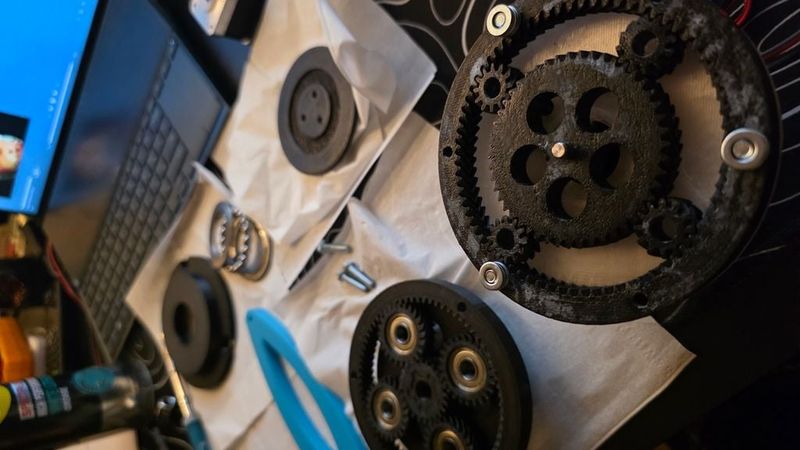
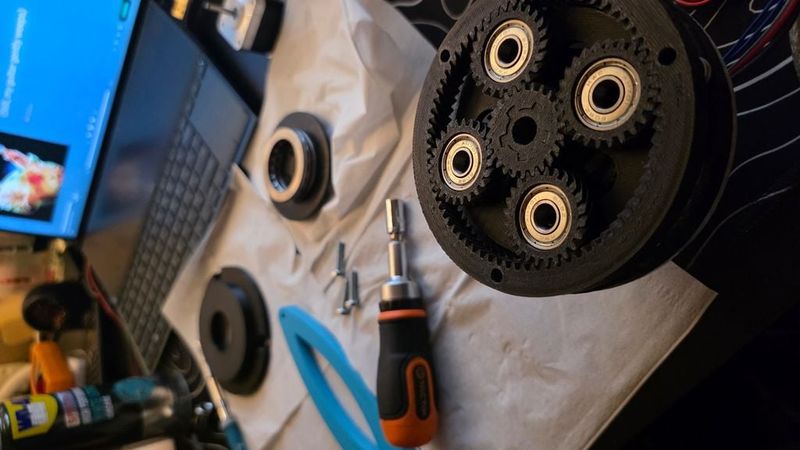
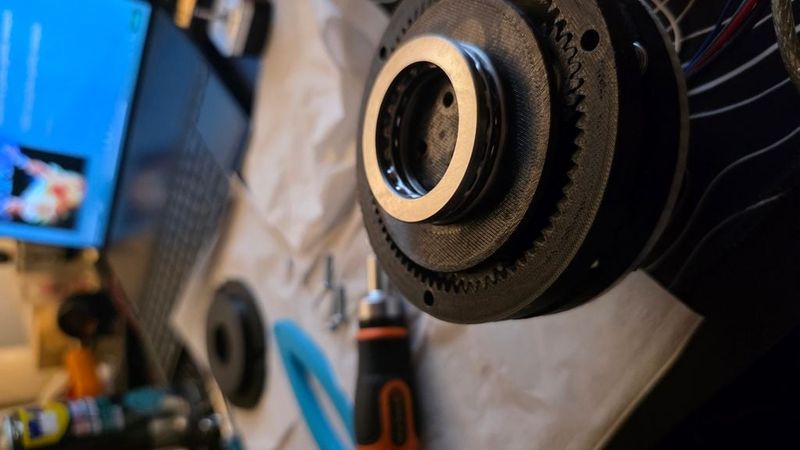
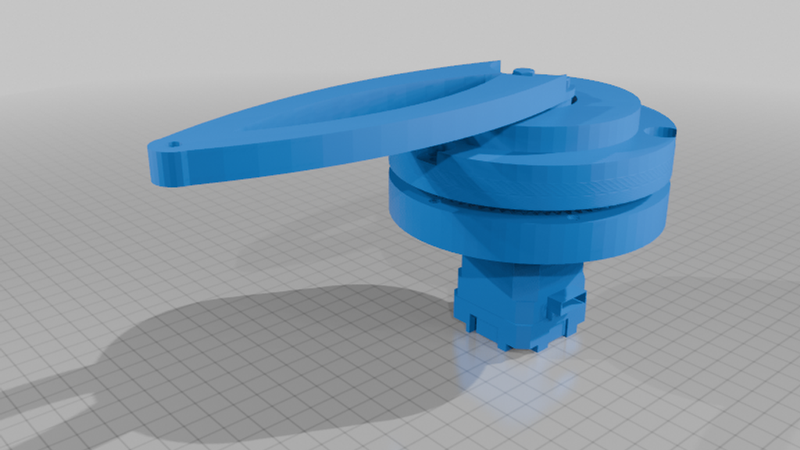
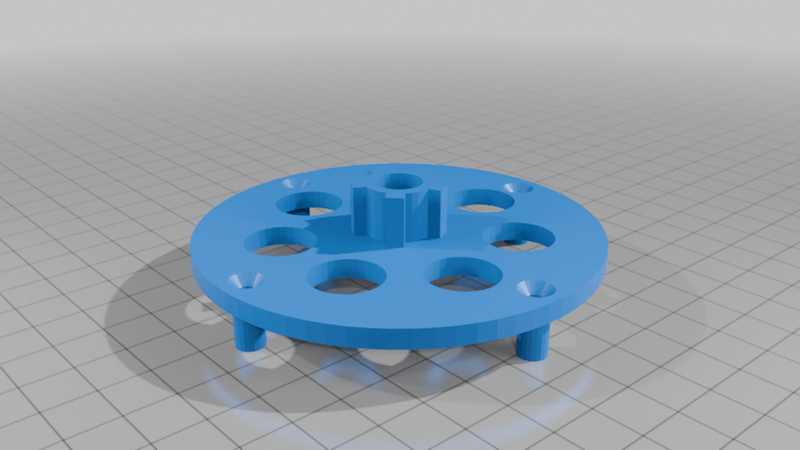
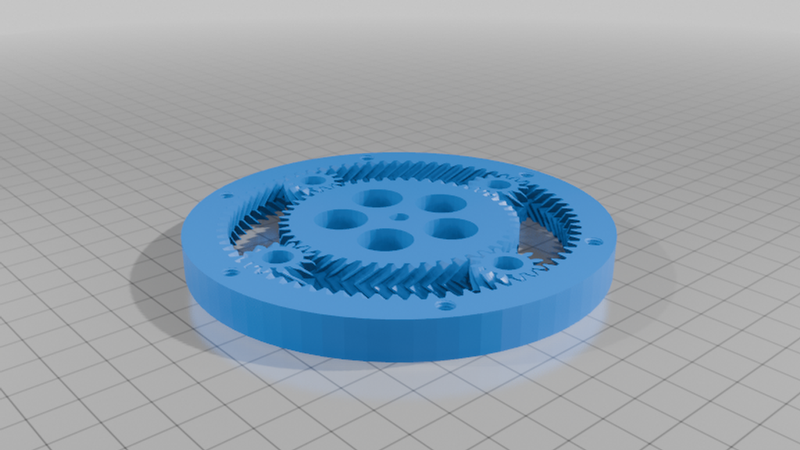
Planetary Gearbox, 10:1, 2 print-in-place gearsets
Ozan2009
9 Files
stl Format
+9
Description
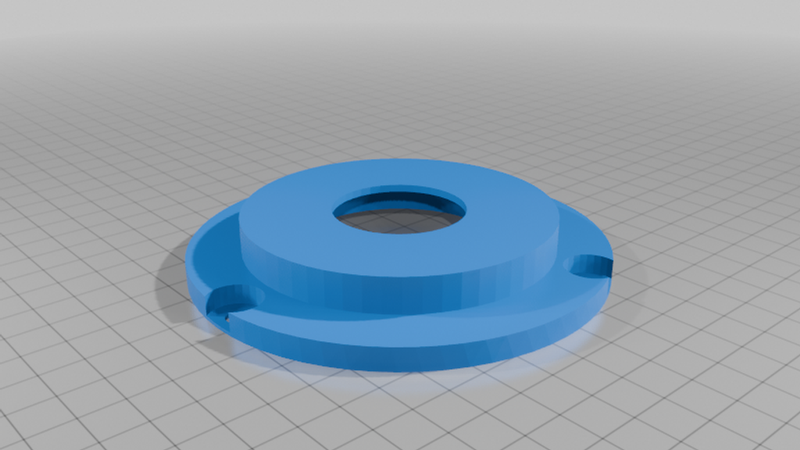
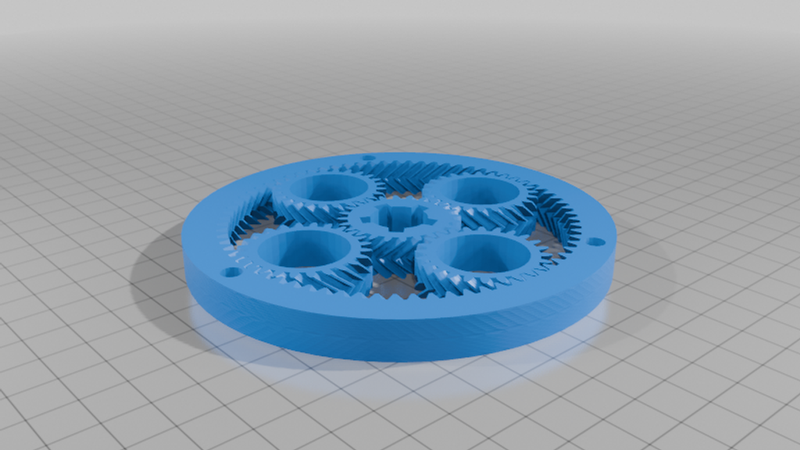
Made to mount on a Nema 17 stepper motor with a reduction ratio of 10 to 1. The tolerances for the gearsets which are print in place is 0.15mm depending on the printer being used these may be too much or too little. For the K1C I used, these tolerances worked just fine.
Parts Required:
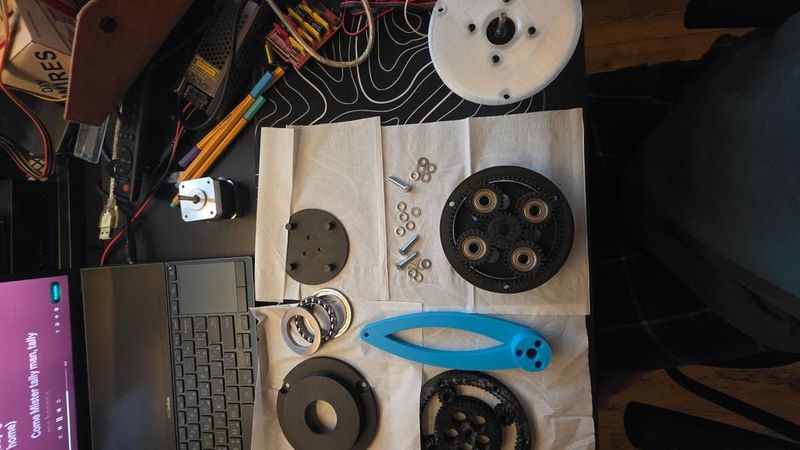
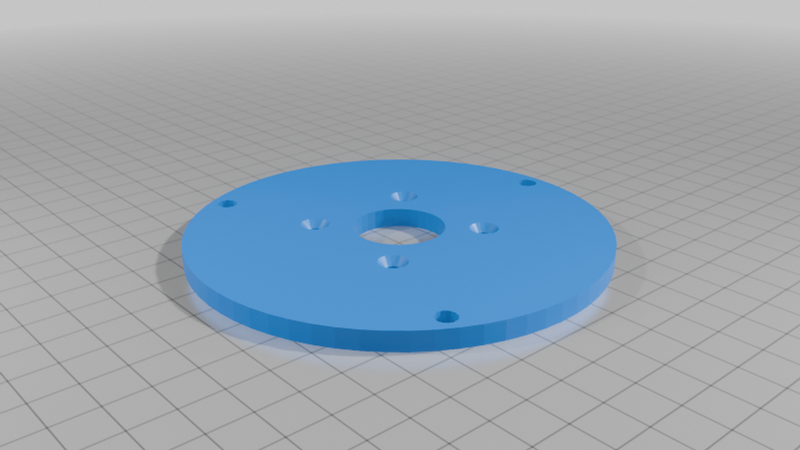
- 4 x m3 screws for mounting on the motor
- 4 x 608zz bearings to be friction fit inside the planet gears of the second stage
- 6 x m5*20 screws going through all the stages
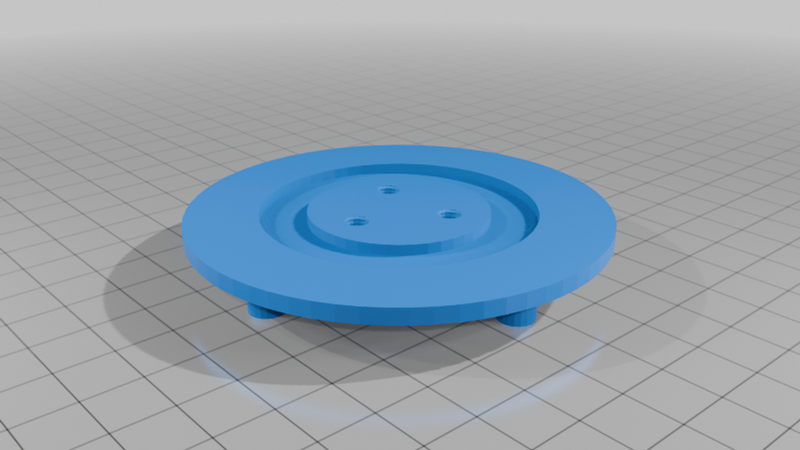
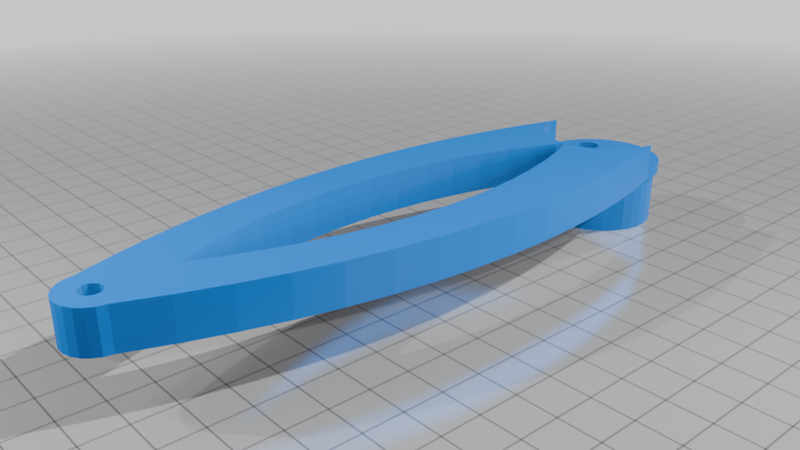
- 3 x m5*20 screws to mount the weight arm
- 1 x 51107 thrust bearing
- 4 x m3*8 to connect the connecting shaft and the pins together
- 4 x (334)mm heated inserts to fit inside the pins of the connecting shaft
Grease helps decrease the friction between the gears, I would recommend it.